 TechIDaily
Loading TechIDaily…
Loading TechIDaily…
Sandflow / Industrial
Hosted on Hugging Face · Runtime not tested
Categories aid discovery; they are not runtime certifications.
Download the complete package with its dependencies.
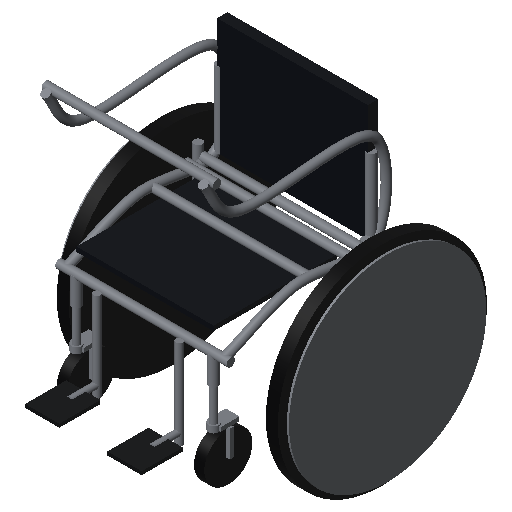
Browse package on HF ↗Parametric Python program with 6 kinematic joints (UsdPhysics). Constructed for autonomous simulation and LLM synthesis.
import sand3d as s3d
import math


def manual_wheelchair():
    frame = wheelchair_frame()
    lrear = rear_wheel(1)
    rrear = rear_wheel(-1)
    lfork = caster_fork()
    rfork = caster_fork()
    lcw = caster_wheel()
    rcw = caster_wheel()
    f1 = s3d.local(frame, -90, 305, 305)
    lrear = s3d.at(lrear, on=f1)
    s3d.joint(class="tok-string">"left_rear_wheel_spin", lrear, f1, kind=class="tok-string">"continuous", axis=class="tok-string">"+Y")
    f2 = s3d.local(frame, -90, -305, 305)
    rrear = s3d.at(rrear, on=f2)
    s3d.joint(class="tok-string">"right_rear_wheel_spin", rrear, f2, kind=class="tok-string">"continuous", axis=class="tok-string">"+Y")
    f3 = s3d.local(frame, 280, 200, 380)
    lfork = s3d.at(lfork, on=f3)
    s3d.joint(class="tok-string">"left_caster_swivel", lfork, f3, kind=class="tok-string">"continuous", axis=class="tok-string">"+Z")
    f4 = s3d.local(frame, 280, -200, 380)
    rfork = s3d.at(rfork, on=f4)
    s3d.joint(class="tok-string">"right_caster_swivel", rfork, f4, kind=class="tok-string">"continuous", axis=class="tok-string">"+Z")
    f5 = s3d.local(lfork, -28, 0, -190)
    lcw = s3d.at(lcw, on=f5)
    s3d.joint(class="tok-string">"left_caster_wheel_spin", lcw, f5, kind=class="tok-string">"continuous", axis=class="tok-string">"+Y")
    f6 = s3d.local(rfork, -28, 0, -190)
    rcw = s3d.at(rcw, on=f6)
    s3d.joint(class="tok-string">"right_caster_wheel_spin", rcw, f6, kind=class="tok-string">"continuous", axis=class="tok-string">"+Y")
    return s3d.assembly(class="tok-string">"manual_wheelchair", frame, lrear, rrear, lfork, rfork, lcw, rcw)


def mat(ob, kind, color):
    return s3d.material(ob, kind, color=color)


def box(name, dims, xyz=(0, 0, 0), rpy=(0, 0, 0), kind=class="tok-string">"steel", color=class="tok-string">"class="tok-comment">#babfc8"):
    o = s3d.extrude(name, s3d.rect(dims[0], dims[1]), dims[2], both=True)
    o = s3d.at(
        o,
        x=xyz[0],
        y=xyz[1],
        z=xyz[2],
        rx=math.degrees(rpy[0]),
        ry=math.degrees(rpy[1]),
        rz=math.degrees(rpy[2]),
    )
    return mat(o, kind, color)


def cyl(name, r, l, xyz=(0, 0, 0), rpy=(0, 0, 0), kind=class="tok-string">"steel", color=class="tok-string">"class="tok-comment">#babfc8"):
    o = s3d.extrude(name, s3d.circle(2 * r), l, both=True)
    o = s3d.at(
        o,
        x=xyz[0],
        y=xyz[1],
        z=xyz[2],
        rx=math.degrees(rpy[0]),
        ry=math.degrees(rpy[1]),
        rz=math.degrees(rpy[2]),
    )
    return mat(o, kind, color)


def wheelchair_frame():
    steel = class="tok-string">"class="tok-comment">#babfc8"
    fabric = class="tok-string">"class="tok-comment">#1a1f29"
    black = class="tok-string">"class="tok-comment">#242628"
    pieces = []
    class="tok-comment"># tube paths are smooth approximations of the welded frame rails
    pts = [
        (340, 230, 930),
        (260, 230, 820),
        (-160, 230, 800),
        (-160, 230, 540),
        (80, 230, 540),
        (280, 230, 460),
    ]
    pieces.append(mat(s3d.wire(class="tok-string">"left_side_frame", s3d.spline(pts), 24), class="tok-string">"steel", steel))
    pts = [
        (340, -230, 930),
        (260, -230, 820),
        (-160, -230, 800),
        (-160, -230, 540),
        (80, -230, 540),
        (280, -230, 460),
    ]
    pieces.append(mat(s3d.wire(class="tok-string">"right_side_frame", s3d.spline(pts), 24), class="tok-string">"steel", steel))
    for n, x, z, l in [
        (class="tok-string">"front_seat_crossbar", 30, 540, 460),
        (class="tok-string">"rear_seat_crossbar", -120, 540, 460),
        (class="tok-string">"front_lower_crossbar", 280, 460, 500),
        (class="tok-string">"push_handle_bar", 320, 930, 500),
        (class="tok-string">"rear_lower_crossbar", -80, 540, 480),
    ]:
        pieces.append(cyl(n, 12, l, (x, 0, z), (math.pi / 2, 0, 0)))
    pieces += [
        cyl(class="tok-string">"left_axle_support", 12, 300, (-120, 245, 420), (0, 0, 0)),
        cyl(class="tok-string">"right_axle_support", 12, 300, (-120, -245, 420), (0, 0, 0)),
    ]
    pieces += [
        cyl(class="tok-string">"left_axle_stub", 14, 30, (-90, 260, 305), (math.pi / 2, 0, 0)),
        cyl(class="tok-string">"right_axle_stub", 14, 30, (-90, -260, 305), (math.pi / 2, 0, 0)),
    ]
    pieces += [
        box(class="tok-string">"seat_sling", (360, 400, 14), (100, 0, 521), kind=class="tok-string">"fabric", color=fabric),
        box(class="tok-string">"backrest_sling", (30, 440, 340), (-165, 0, 710), kind=class="tok-string">"fabric", color=fabric),
    ]
    for side, y in [(class="tok-string">"left", 220), (class="tok-string">"right", -220)]:
        pieces.append(cyl(side + class="tok-string">"_backrest_sleeve", 13, 220, (-160, y, 650)))
    for side, y in [(class="tok-string">"left", 120), (class="tok-string">"right", -120)]:
        pieces.append(cyl(side + class="tok-string">"_footrest_hanger", 10, 260, (300, y, 330)))
        pieces.append(cyl(side + class="tok-string">"_footrest_support", 9, 80, (340, y, 230), (0, math.pi / 2, 0)))
        pieces.append(
            box(side + class="tok-string">"_footplate", (120, 100, 10), (400, y, 230), kind=class="tok-string">"plastic", color=black)
        )
    for side, y in [(class="tok-string">"left", 200), (class="tok-string">"right", -200)]:
        pieces.append(cyl(side + class="tok-string">"_caster_receiver", 13, 80, (280, y, 420)))
    return s3d.group(class="tok-string">"frame", *pieces)


def rear_wheel(side):
    rubber = class="tok-string">"class="tok-comment">#141416"
    metal = class="tok-string">"class="tok-comment">#d1d6de"
    steel = class="tok-string">"class="tok-comment">#babfc8"
    y = 30 * side
    p = [
        cyl(class="tok-string">"tire", 305, 35, (0, 0, 0), (math.pi / 2, 0, 0), class="tok-string">"rubber", rubber),
        cyl(class="tok-string">"rim", 270, 22, (0, 0, 0), (math.pi / 2, 0, 0), class="tok-string">"aluminium", metal),
        cyl(class="tok-string">"hub", 36, 60, (0, 0, 0), (math.pi / 2, 0, 0)),
    ]
    for i, a in enumerate((0, math.pi / 3, 2 * math.pi / 3)):
        p.append(box(class="tok-string">"spoke_" + str(i), (470, 6, 12), (0, 0, 0), (0, a, 0), class="tok-string">"aluminium", metal))
    p.append(cyl(class="tok-string">"pushrim", 288, 6, (0, y, 0), (math.pi / 2, 0, 0)))
    for i, a in enumerate((0, 2 * math.pi / 3, 4 * math.pi / 3)):
        p.append(
            box(
                class="tok-string">"pushrim_standoff_" + str(i),
                (50, 6, 6),
                (205 * math.cos(a), y * 0.5, 205 * math.sin(a)),
                (0, a, 0),
            )
        )
    return s3d.group(class="tok-string">"rear_wheel", *p)


def caster_fork():
    p = [
        cyl(class="tok-string">"stem", 10, 100, (0, 0, -50)),
        cyl(class="tok-string">"crown", 15, 18, (0, 0, -105)),
        box(class="tok-string">"fork_bridge", (55, 40, 12), (-28, 0, -105)),
        box(class="tok-string">"outer_leg", (12, 10, 78), (-28, 20, -150)),
        box(class="tok-string">"inner_leg", (12, 10, 78), (-28, -20, -150)),
    ]
    return s3d.group(class="tok-string">"caster_fork", *p)


def caster_wheel():
    p = [
        cyl(class="tok-string">"tire", 70, 30, (0, 0, 0), (math.pi / 2, 0, 0), class="tok-string">"rubber", class="tok-string">"class="tok-comment">#141416"),
        cyl(class="tok-string">"rim", 52, 20, (0, 0, 0), (math.pi / 2, 0, 0), class="tok-string">"aluminium", class="tok-string">"class="tok-comment">#d1d6de"),
        cyl(class="tok-string">"hub", 16, 18, (0, 0, 0), (math.pi / 2, 0, 0)),
        box(class="tok-string">"spoke_bar", (90, 6, 10), kind=class="tok-string">"aluminium", color=class="tok-string">"class="tok-comment">#d1d6de"),
    ]
    return s3d.group(class="tok-string">"caster_wheel", *p)
🚀 Sand3D Modeling Engine: Open Interactive Sand3D Explorer Space ↗
Sandflow Sand3D Library; CC-BY-4.0
Hosted on Hugging Face: SZFSPC/techidaily-resourcesba1baf9d89ddf57433d7c47cb461f6d8883067a1
Revision: ba1baf9d89ddf57433d7c47cb461f6d8883067a1
licenseSHA-256:
commercialPermittedSHA-256:
notesSHA-256:
